LoRA rank allocation
Under reviewA matched-control study of probe-based rank allocation for LoRA across five seeds, three decoders and eight tasks, reporting a negative result honestly.
ML systems from data to deployment: PyTorch and PEFT pipelines, annotation stacks with SAM and YOLO, TensorRT and TensorFlow Lite at the edge.
BSc Computer Science, BRAC University, Dhaka. Expected graduation January 2027. Available remotely from January 2027.
Computer Science undergraduate at BRAC University who builds ML systems from data to deployment. Built PyTorch training and PEFT pipelines (LoRA, AdaLoRA, TSDLoRA) with Optuna hyperparameter search; dataset collection, labeling and semi-automatic annotation stacks using SAM and YOLO-family detectors; and edge inference with TensorRT on a competition robot and TensorFlow Lite on Raspberry Pi with post-training quantization.
Comfortable in Python, C++ and TypeScript, from CLI and web-portal tooling to ROS 2 nodes, with tested, reproducible pipelines.
A matched-control study of probe-based rank allocation for LoRA across five seeds, three decoders and eight tasks, reporting a negative result honestly.
Semi-automatic annotation pipeline that combines a COCO detector, a regionally fine-tuned detector and foundation-model segmentation lifted into the LiDAR point cloud, over 14 h 35 min of dense Dhaka traffic.
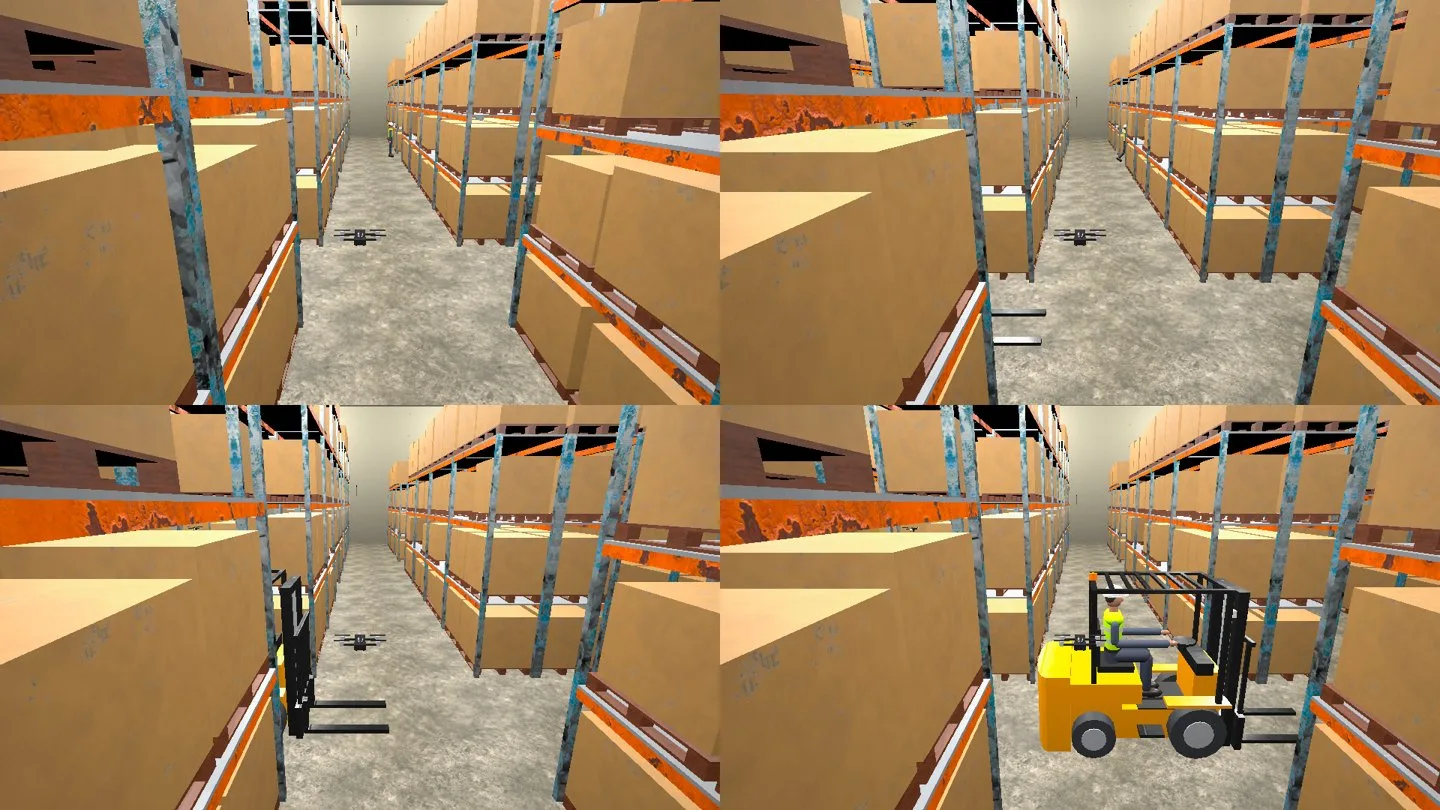
Event plus RGB captures of rule-breaking hazards across five seeded industrial environment families with exact label geometry and QC gates.
Three-stage pipeline behind the thesis experiments: Optuna/TPE hyperparameter search, multi-seed retraining of 3 methods × 3 backbones × 8 GLUE tasks (72 combinations, 5 seeds each) through a CLI or a web portal, and an analysis stage producing mean ± std tables, single-signal ablations and Wilcoxon tests.
In-vehicle recording stack with supervisor and watchdog, PPK-corrected INS trajectories, a remote export pipeline that hashes hundreds of GB where they live, and a semi-automatic 3-D labelling pipeline lifting foundation-model segmentation into the LiDAR cloud. Private repository.
Python toolkit and Claude Code skill that builds label-correct, sensor-clean, licence-clean, reproducible simulation environments for Unreal Engine 5 / Cosys-AirSim and Isaac Sim / USD from CC0 and CC-BY assets with provenance; parity, null-test and licence gates; 289 tests.
EchoMind: a TypeScript wrapper for locally hosted vision-language models with an API-driven, asynchronous client-server loop. my_bot: a ROS 2 mobile robot with full URDF, Nav2 and LiDAR/IMU SLAM in simulation.
Event-based surveillance benchmark tooling: corrected ESIM event synthesis, class-agnostic RGB and event detector baselines, dt-aware SORT tracking and a time-to-first-detection metric; now the capture infrastructure behind COVE. Private repository.
Listed by title only: no PDFs, and no figures, from manuscripts under review or in preparation. No author lists for unpublished work.
Five-seed, budget-matched comparison of a probe-based rank allocator against uniform-rank LoRA, LoRA and GoRA on eight commonsense tasks across three decoders plus 11 of 24 GLUE cells; the allocator trails the matched control in 26 of 35 cells.
14 h 35 min across 175 scenes from a Livox Mid-360, stereo depth, six RGB cameras and post-processed GNSS/INS, with CNG auto-rickshaws and cycle rickshaws as 3D classes and every metric reported per traffic-density level.
A rover drives only on ground it has certified: step, slope and body clearance pass with a distribution-free margin on the map's own uncertainty; a decidability rule predicts which depth sensor can certify which rover; when nothing ahead is certified, active perception picks the viewpoint that resolves the most blocking cells per second. Validated in Isaac Sim before deployment on a real rover.
The first collaborative-perception system whose shared representation is event-derived, with a counterfactually supervised, recipient-specific gate deciding what crosses the link; simulation study in Unreal Engine 5.8 / Cosys-AirSim.
Five industrial environment families with seeded layouts, exact label geometry, QC gates and rule-breaking hazard speeds, captured with event and RGB cameras.
The CV and this page say the same things; the CV has the detail.